01
Linked component histories.
Follow each actuator, encoder and board inside the finished robot.
INDUSTRIES / ROBOTICS & AUTOMATION
Connect actuator tests, calibration results, and final assembly checks. Follow a failure from the robot back to the component and the test that measured it.
01
Follow each actuator, encoder and board inside the finished robot.
02
Keep offsets, limits and test versions with the original reading.
03
Compare the joint’s measurements across stations, batches and retests.
WORKFLOW EXAMPLE
An example workflow for a robotics team, using linked units, measurement limits, and a failure notification.
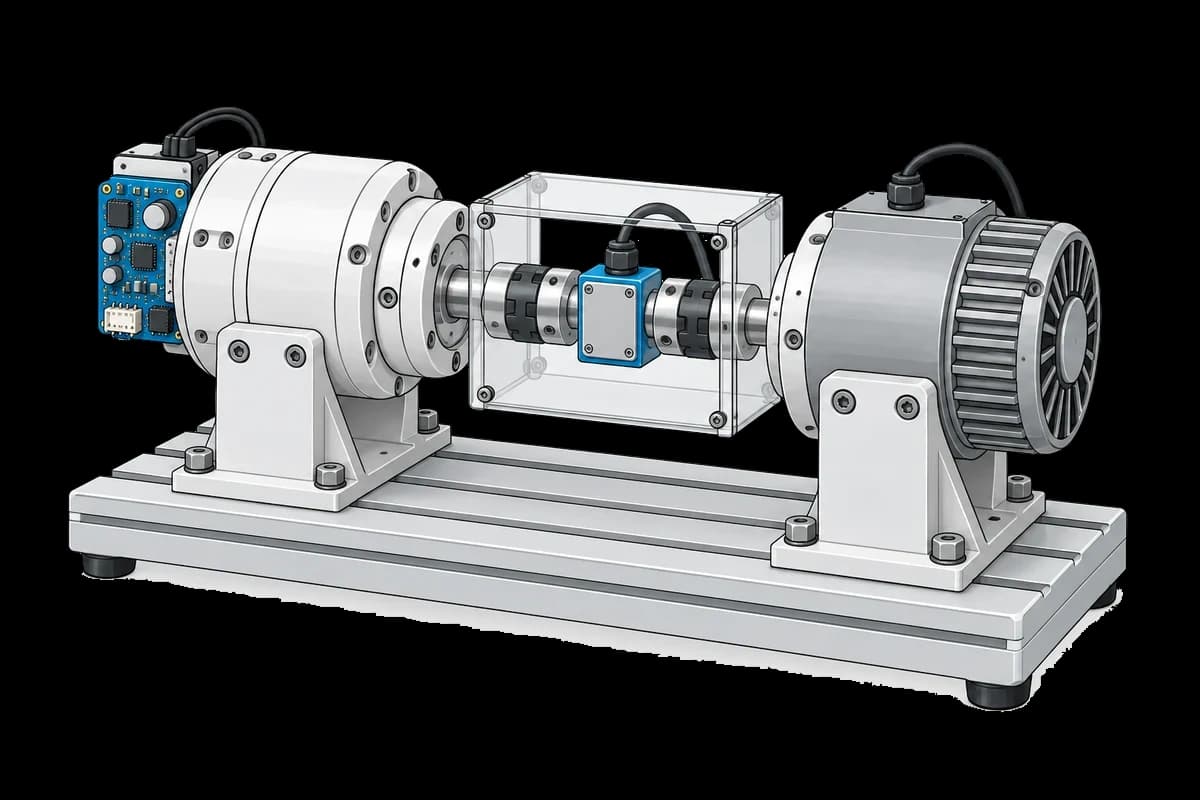
Linked unit records
Record current, travel, and encoder offset against the actuator serial.
Attach the actuator and control board as sub-units of the arm.
Keep the final motion-test result with the assembly and its test version.
Notify the test team with the run link. Compare the actuator’s calibration and retest before returning the arm to the line.
Connect the next stepCUSTOMER PERSPECTIVE
“TofuPilot gives us a clear, well-organized view of our testing results. New features keep rolling in, making it even easier to explore and analyze our data.”
RESOURCES
Establish a repeatable reference position for each robot joint.
OPEN TEMPLATECycle temperature and compensate each sensor’s measurement drift.
OPEN TEMPLATELearn how to automate motor and actuator production tests, capture torque, speed, and vibration data, and track results with TofuPilot.
PRACTICAL GUIDEBring one procedure and a representative set of results. We’ll help you plan the first integration.